Live exhibits · five machines
Anatomy
Cutaway machines drawn as isometric SVG and set on test rigs, with the mechanism running while you watch. Move the controls, change the load, and see what the part actually does. Every figure is a single self-contained HTML file: no framework, no network calls.
-
Fig 1
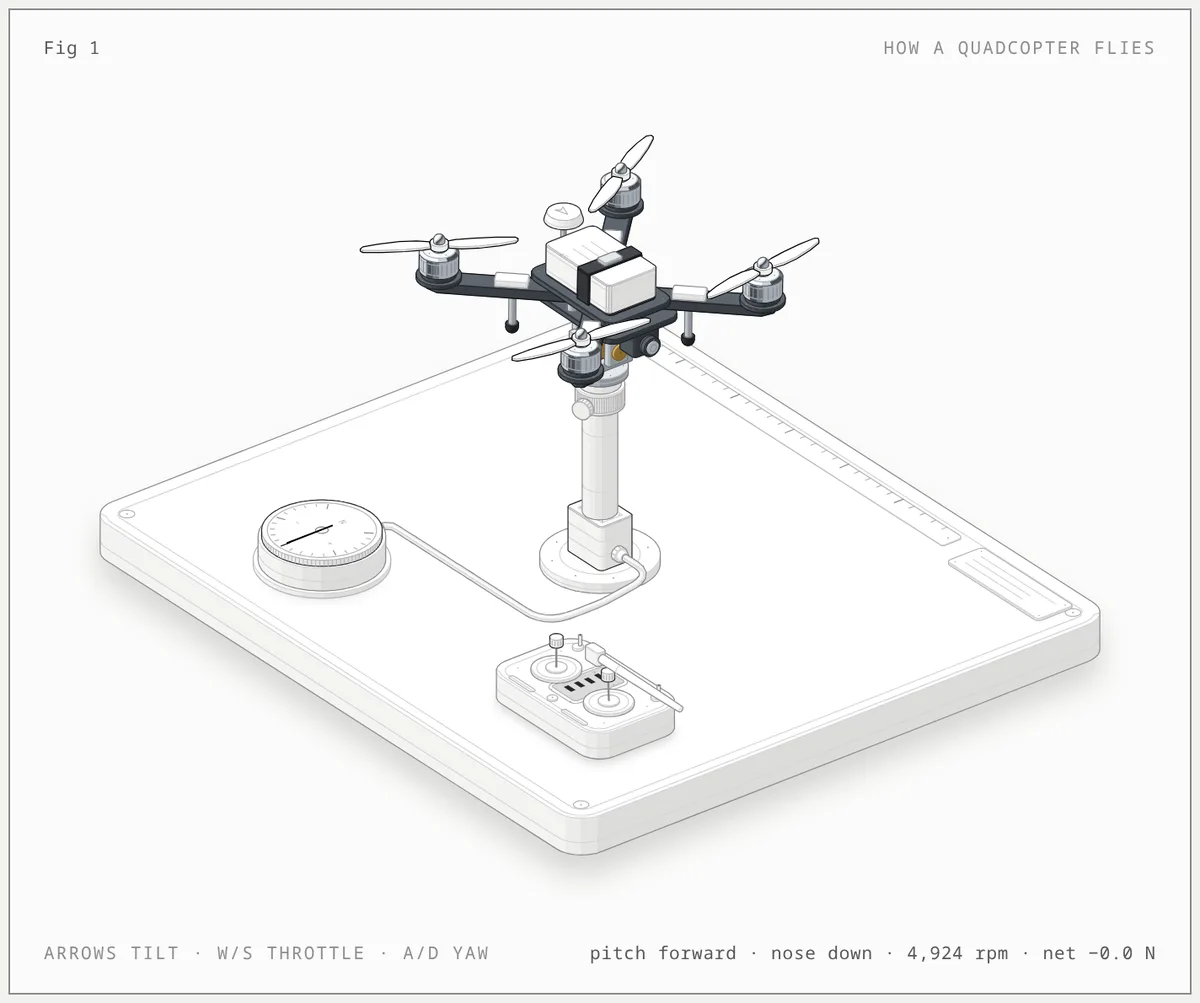
How a quadcopter flies
A class 450 quadcopter on a two-axis gimbal rig with a universal joint and load-cell sensor. The transmitter drives throttle, pitch, roll and the yaw reaction torques.
-
Fig 2
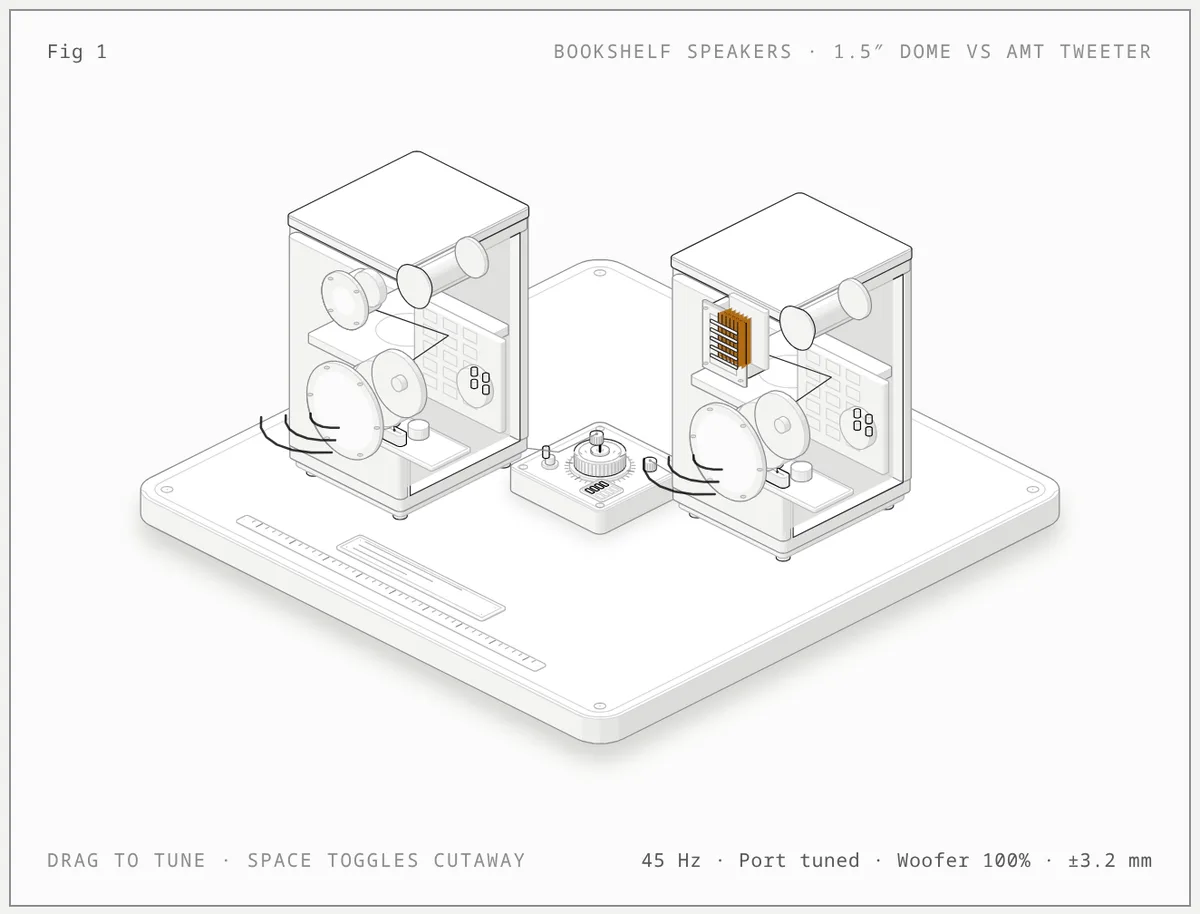
Bookshelf speakers · Dome vs AMT
A pair of reference monitors on a slate inspection bench, with an acoustic probe, a laser interferometry beam and a frequency-generator sweep comparing a dome tweeter against an air-motion transformer.
-
Fig 3
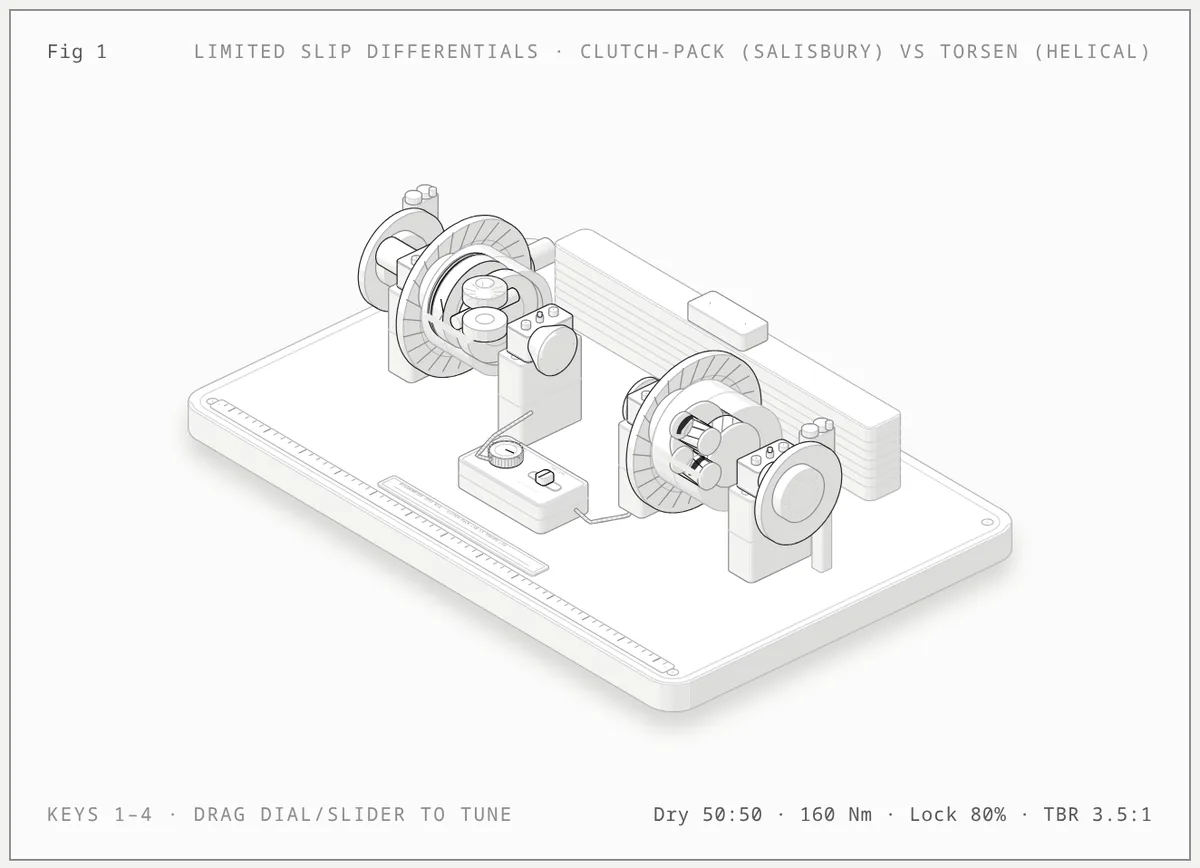
Limited-slip differential · Clutch vs Torsen
A bench dynamometer with twin roller dynos and a cross-shaft drive, plus a cutaway carrier comparing clutch-pack preload against worm-gear torque biasing across four scenarios.
-
Fig 4
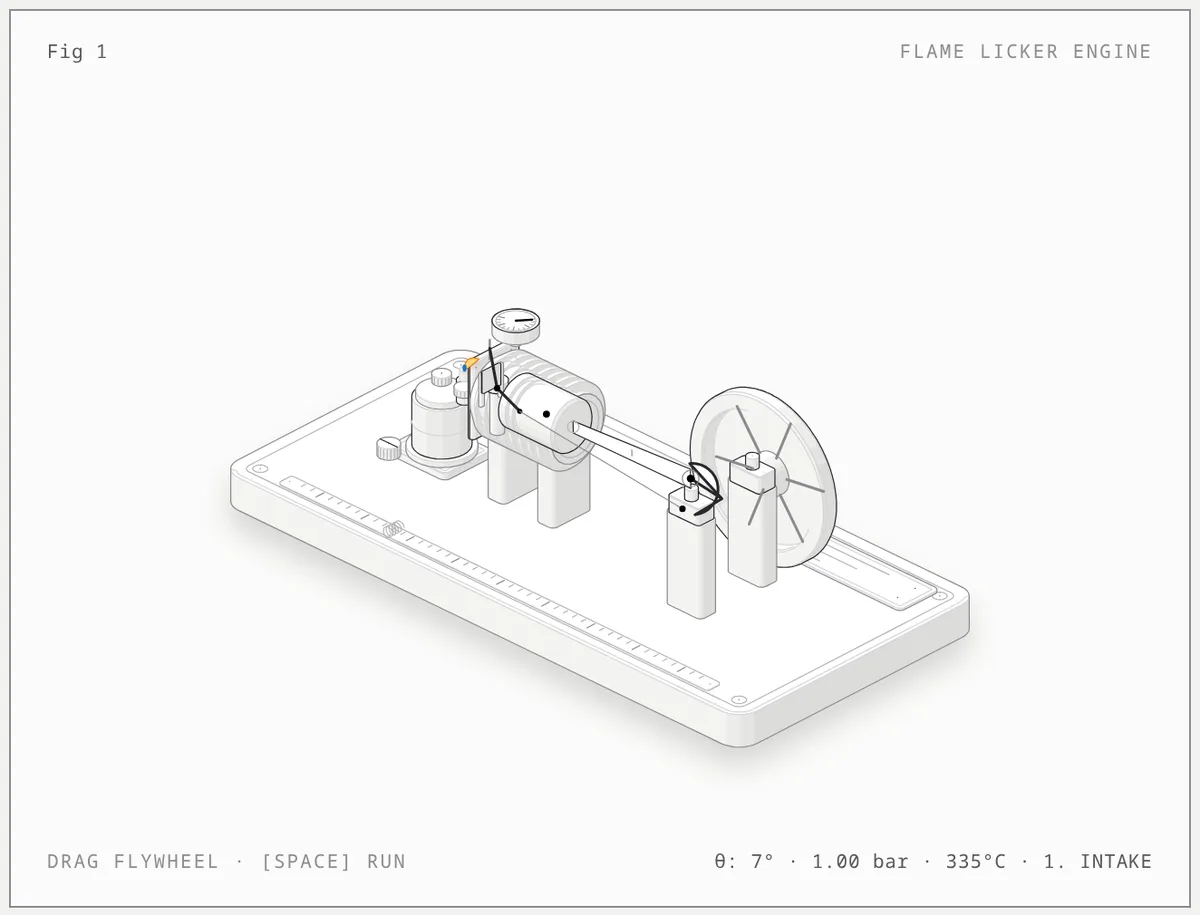
Flame-licker engine
An atmospheric vacuum engine: brass cylinder, slide valve, spirit-lamp flame and a heavy flywheel, running through the closed cycle that draws the piston in and drives the wheel round.
-
Fig 5
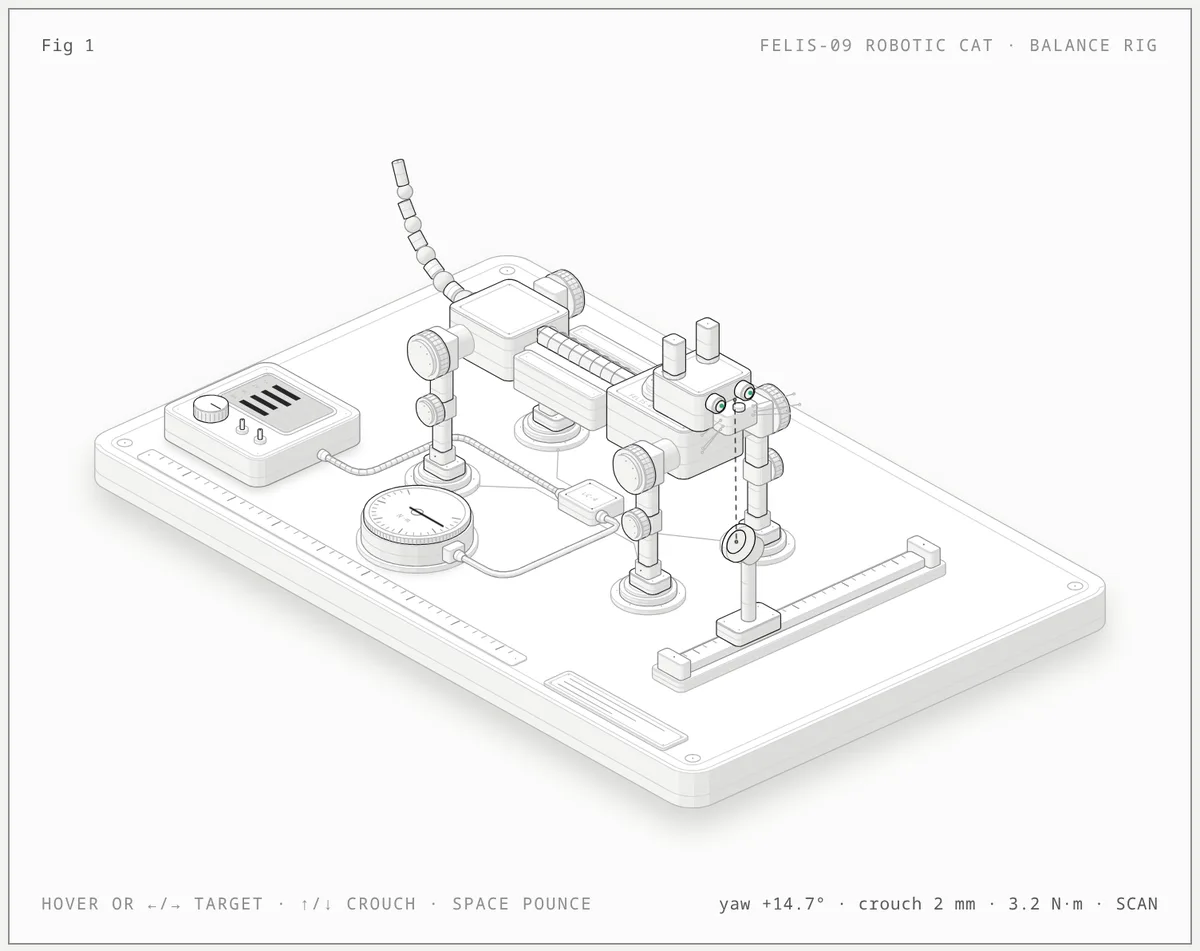
FELIS-09 robotic cat
A 9.2 kg quadruped on a balance rig: four strain-gauge load pads, an optical collimator on a front rail commanding gaze yaw, a five-link counterbalance tail, and a 38 mm suspension crouch that moves the torque across the harmonic-drive knees.